가벼운 충돌 후 터치 테스트 실패(로봇 위치 정확도 저하)
문제
After a mild collision, your robot positioning accuracy is compromised. This is observed as offsets in object picking/placement and failed touch tests, where the robot’s tool tip does not land on the expected point.
충돌 전에는 핸드-아이 캘리브레이션 결과가 양호했고, 터치 테스트도 성공적으로 통과했습니다.
핸드-아이 캘리브레이션 변환 |
핸드-아이 캘리브레이션 잔차 |
프로젝션 검증 |
터치 테스트 |
|---|---|---|---|
합리적인 |
좋은 |
좋은 |
좋음 → 충돌 → 나쁨 |
우수한 핸드-아이 캘리브레이션 결과의 예
핸드-아이 캘리브레이션 행렬은 합리적이며 대략적인 수동 측정에서 예상되는 결과와 일치합니다(아래 표 및 이미지 참조).
0.999 |
-0.002 |
0.0412 |
-55.598 |
0.001 |
0.999 |
0.0283 |
-90.654 |
-0.041 |
-0.028 |
0.998 |
129.044 |
0 |
0 |
0 |
1 |
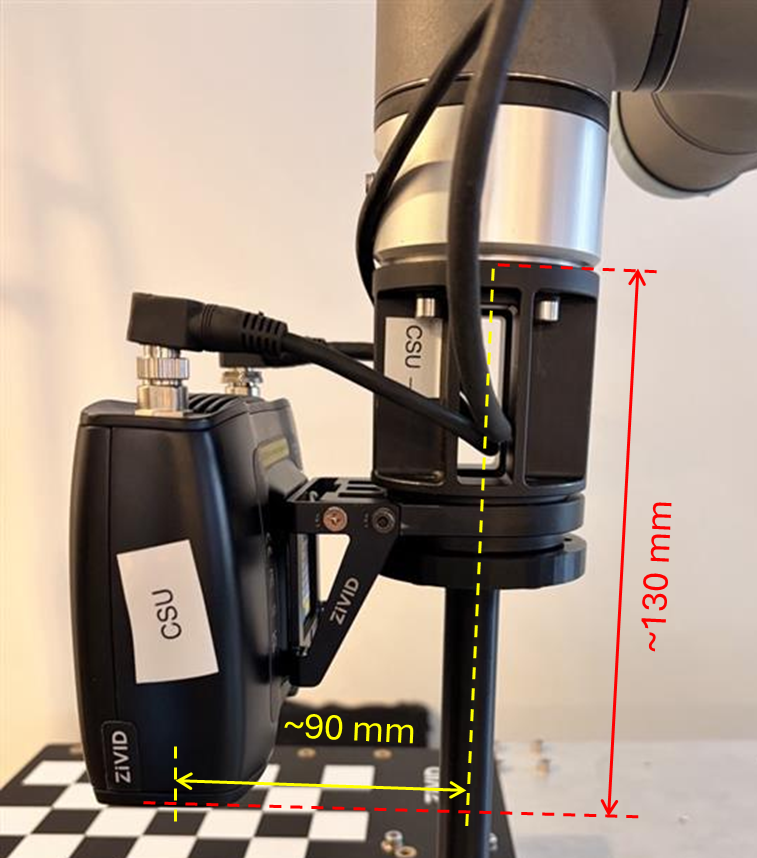
보정 잔차가 허용 가능한 범위 내에 있으므로 최적화가 성공적으로 수렴되었음을 나타냅니다.
N (포즈) |
회전 평균 (°) |
최대 회전각(°) |
이동 평균(mm) |
최대 이동 거리(mm) |
|---|---|---|---|---|
10 |
0.021 |
0.042 |
0.109 |
0.172 |
For smaller robots, we expect the residuals to be in the sub-millimeter range, while for larger robots, the residuals can be in the millimeter range. As for the rotational component of the residuals, we expect them to be in the sub-degree range.
전체 잔차
포즈 |
회전 (°) |
이동 (mm) |
|---|---|---|
1 |
0.017292 |
0.163 |
2 |
0.008218 |
0.135 |
3 |
0.028 |
0.172 |
4 |
0.009 |
0.053 |
5 |
0.042 |
0.080 |
6 |
0.008 |
0.098 |
7 |
0.022 |
0.138 |
8 |
0.025 |
0.077 |
9 |
0.036 |
0.125 |
10 |
0.013 |
0.048 |
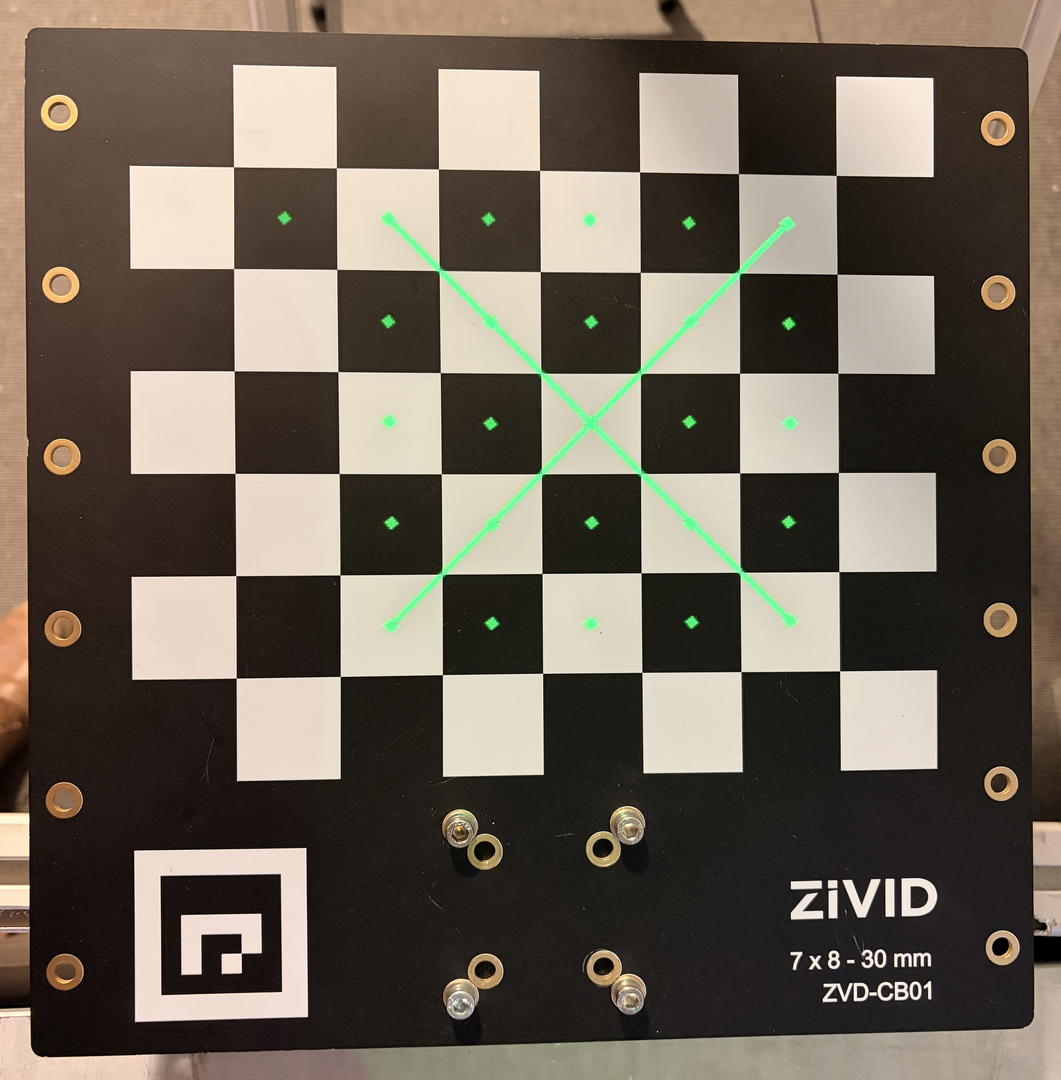
프로젝션을 이용한 검증 또한 통과하여 핸드-아이 변환이 정확하고 정밀함을 나타냅니다.
잠재적 원인
Mild collisions can cause slight shifts in the robot’s joints or end-effector, which are not always severe enough to cause visible damage but can still affect the accuracy of the hand-eye calibration. This can result in failed touch tests and inaccurate robot positioning.
잠재적 해결책
카메라를 예열하고 현장 보정을 수행하십시오.
초기 데이터 세트를 사용하여 핸드-아이 캘리브레이션을 반복합니다.
핸드-아이 캘리브레이션 결과 (변환, 잔차, 프로젝션)를 검증합니다.
터치 테스트를 다시 시도하세요.