焦深
介绍
焦深描述了是物体聚焦的距离范围。超出此范围的物体会显得模糊。
在本文中,我们将解释焦深的基本原理以及如何将这些原理应用于 Zivid 相机。
什么是焦点?
焦点通常由所谓的*Circle of Confusion*(弥散圆)或简称 CoC 定义。 CoC是指光线在通过相机镜头后撞击成像传感器时,其所覆盖的半径或面积。通常,当CoC大到会覆盖一个以上像素时,就会认为对象失焦。这会导致信号丢失和噪声。当光圈足够大时,距离太近的物体会聚焦在图像传感器的前方,而距离镜头太远的物体会聚焦在传感器后方,两者都会导致模糊。请参见下图。
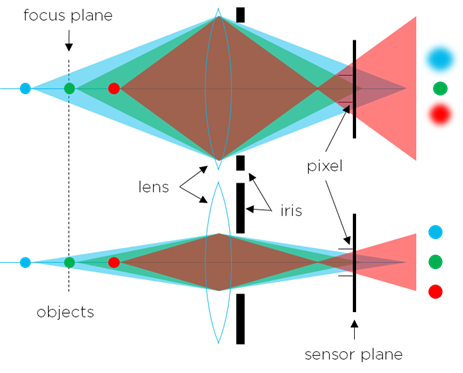
景深
景深是物体能够被正常聚焦的前后距离范围。其边界由近焦距 ( \(d_{near}\) ) 和远焦距 ( \(d_{far}\) ) 定义。在这些边界之外,CoC 会增大,导致光线扩散到相邻像素中。
镜头折射光线的角度会随着光圈大小而增大。对于 Zivid 3D 相机,大光圈会导致物体失焦,从而降低信噪比 (SNR) 并使点云更加嘈杂。因此,选择适合相机工作距离的光圈对于获得最佳图像质量至关重要。
焦点如何影响我的点云?
As the image gets more out of focus, artifacts such as noise and 对比度失真 will increase. When we speak about noise, we are talking about the point precision of the point cloud. This means that the capture-to-capture variations of a given pixel will increase and that the pixel-to-pixel variation within for a given capture will increase. A slight increase in noise is often still acceptable, depending on the processing algorithm used. Therefore, an unfocused image can still be acceptable in many cases.
备注
Zivid 相机具有很强的防失焦能力!
还需要注意的是,只有图像的失焦区域才会受到影响。考虑相机在给定应用中的工作距离,以获得具有最佳精度的良好点云。
Zivid 相机的焦深
下表显示了 Zivid 相机的焦深。
Zivid 2+
MR130/M130
Zivid 2+ M130/MR130 |
|||||||||
|---|---|---|---|---|---|---|---|---|---|
\(f\) -值 |
\(f/2\) |
\(f/2.8\) |
\(f/4\) |
\(f/5.6\) |
\(f/8\) |
\(f/11\) |
\(f/16\) |
\(f/22\) |
\(f/32\) |
Stops |
+3 |
+2 |
+1 |
0 |
-1 |
-2 |
-3 |
-4 |
-5 |
近焦点 (mm) |
1115 |
1055 |
975 |
885 |
780 |
680 |
560 |
460 |
355 |
远焦点(mm) |
1560 |
1695 |
1945 |
2430 |
3880 |
15120 |
Inf [2] |
Inf [2] |
Inf [2] |
景深 (mm) |
445 |
640 |
970 |
1545 |
3095 |
14440 |
Inf [2] |
Inf [2] |
Inf [2] |
LR110/L110
Zivid 2+ L110/LR110 |
|||||||||
|---|---|---|---|---|---|---|---|---|---|
\(f\) -值 |
\(f/2\) |
\(f/2.8\) |
\(f/4\) |
\(f/5.6\) |
\(f/8\) |
\(f/11\) |
\(f/16\) |
\(f/22\) |
\(f/32\) |
Stops |
+3 |
+2 |
+1 |
0 |
-1 |
-2 |
-3 |
-4 |
-5 |
近焦点 (mm) |
800 |
720 |
630 |
535 |
440 |
360 |
275 |
215 |
155 |
远焦点(mm) |
1769 |
2310 |
4375 |
Inf [3] |
Inf [3] |
Inf [3] |
Inf [3] |
Inf [3] |
Inf [3] |
景深 (mm) |
960 |
1590 |
3745 |
Inf [3] |
Inf [3] |
Inf [3] |
Inf [3] |
Inf [3] |
Inf [3] |
MR60/M60
Zivid 2+ M60/MR60 |
|||||||||
|---|---|---|---|---|---|---|---|---|---|
\(f\) -值 |
\(f/2\) |
\(f/2.8\) |
\(f/4\) |
\(f/5.6\) |
\(f/8\) |
\(f/11\) |
\(f/16\) |
\(f/22\) |
\(f/32\) |
Stops |
+3 |
+2 |
+1 |
0 |
-1 |
-2 |
-3 |
-4 |
-5 |
近焦点 (mm) |
500 |
465 |
425 |
380 |
330 |
285 |
230 |
185 |
140 |
远焦点(mm) |
755 |
840 |
1010 |
1390 |
3200 |
Inf [4] |
Inf [4] |
Inf [4] |
Inf [4] |
景深 (mm) |
255 |
370 |
585 |
1010 |
2870 |
Inf [4] |
Inf [4] |
Inf [4] |
Inf [4] |
Zivid 2
M70
Zivid 2 M70 |
|||||||||
|---|---|---|---|---|---|---|---|---|---|
\(f\) -值 |
\(f/2\) |
\(f/2.8\) |
\(f/4\) |
\(f/5.6\) |
\(f/8\) |
\(f/11\) |
\(f/16\) |
\(f/22\) |
\(f/32\) |
Stops |
+3 |
+2 |
+1 |
0 |
-1 |
-2 |
-3 |
-4 |
-5 |
近焦点 (mm) |
530 |
480 |
420 |
370 |
300 |
250 |
190 |
150 |
110 |
远焦点(mm) |
1040 |
1280 |
1990 |
7630 |
Inf [5] |
Inf [5] |
Inf [5] |
Inf [5] |
Inf [5] |
景深 (mm) |
510 |
800 |
1570 |
7260 |
Inf [5] |
Inf [5] |
Inf [5] |
Inf [5] |
Inf [5] |
L100
Zivid 2 L100 |
|||||||||
|---|---|---|---|---|---|---|---|---|---|
\(f\) -值 |
\(f/2\) |
\(f/2.8\) |
\(f/4\) |
\(f/5.6\) |
\(f/8\) |
\(f/11\) |
\(f/16\) |
\(f/22\) |
\(f/32\) |
Stops |
+3 |
+2 |
+1 |
0 |
-1 |
-2 |
-3 |
-4 |
-5 |
近焦点 (mm) |
680 |
605 |
520 |
430 |
350 |
280 |
210 |
160 |
120 |
远焦点(mm) |
1870 |
2870 |
14290 |
Inf [6] |
Inf [6] |
Inf [6] |
Inf [6] |
Inf [6] |
Inf [6] |
景深 (mm) |
1190 |
2260 |
13770 |
Inf [6] |
Inf [6] |
Inf [6] |
Inf [6] |
Inf [6] |
Inf [6] |
警告
Zivid 3 采用固定光圈,不具备光圈调节功能。
焦深计算器
By using Zivid's depth of focus calculator, it is possible to find the recommended max aperture based on the working distance and acceptable blur radius. Keep in mind, getting sharp images in the region of interest is one of many things needed for optimal point cloud quality, but it is not a hard constraint. Zivid's 3D technology is very resilient to blur and defocus. It will still be able to provide good point clouds even if the image appears out of focus, though they can be a little noisier.
版本历史记录
SDK |
变更 |
|---|---|
2.17.0 |
新增对 Zivid 3 XL250 的支持。 |